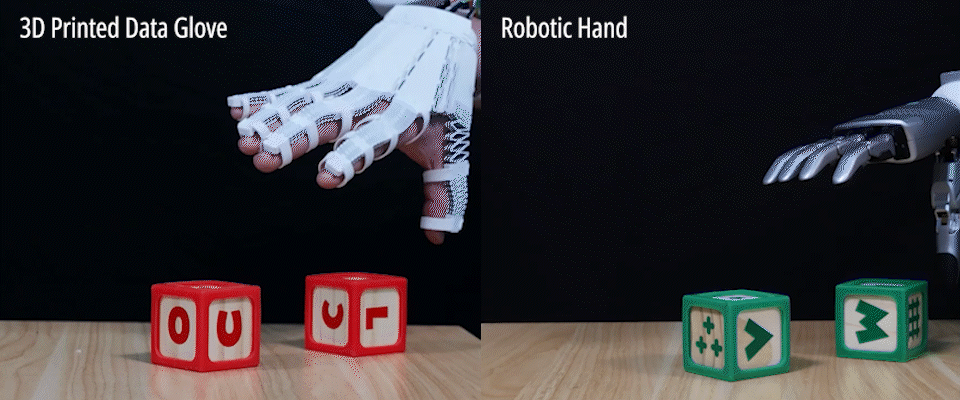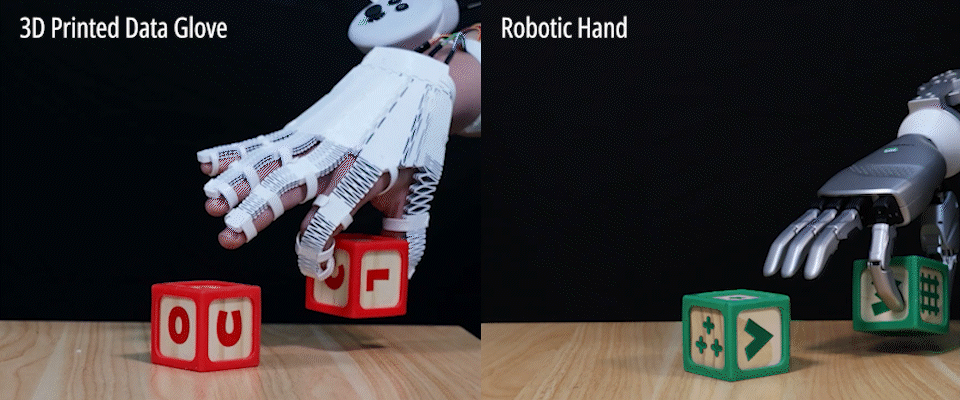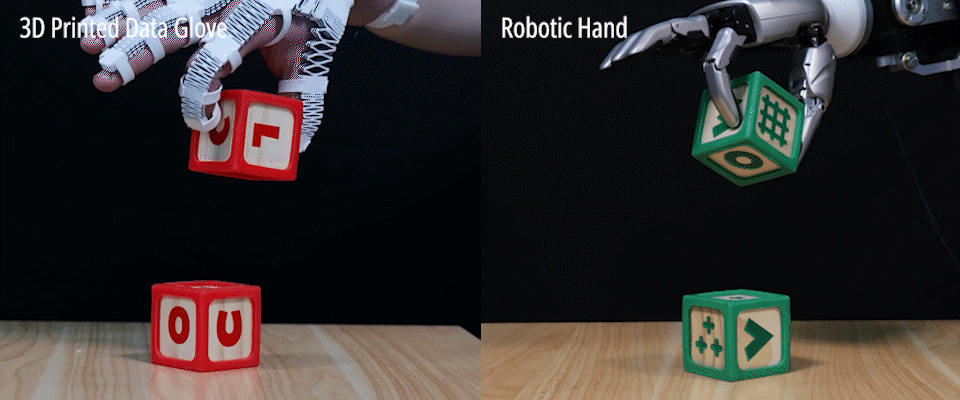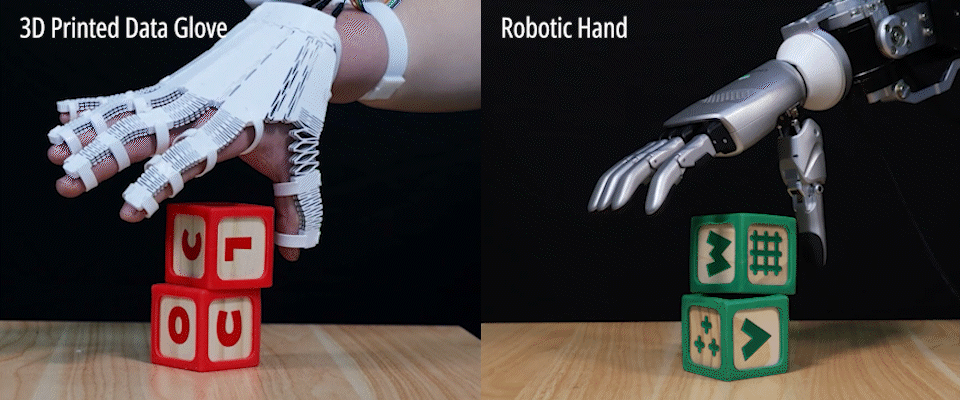
As a child, you likely saw a few Disney movies depicting inanimate objects, such as clocks, cups, and toys, as interactive companions to humans — an act of pure magic, seemingly. But scientists at MIT’s Computer Science and Artificial Intelligence Laboratory (CSAIL) are now doing something similar: transforming stationary items into self-aware tools that perceive and respond to human motion to complete a task.
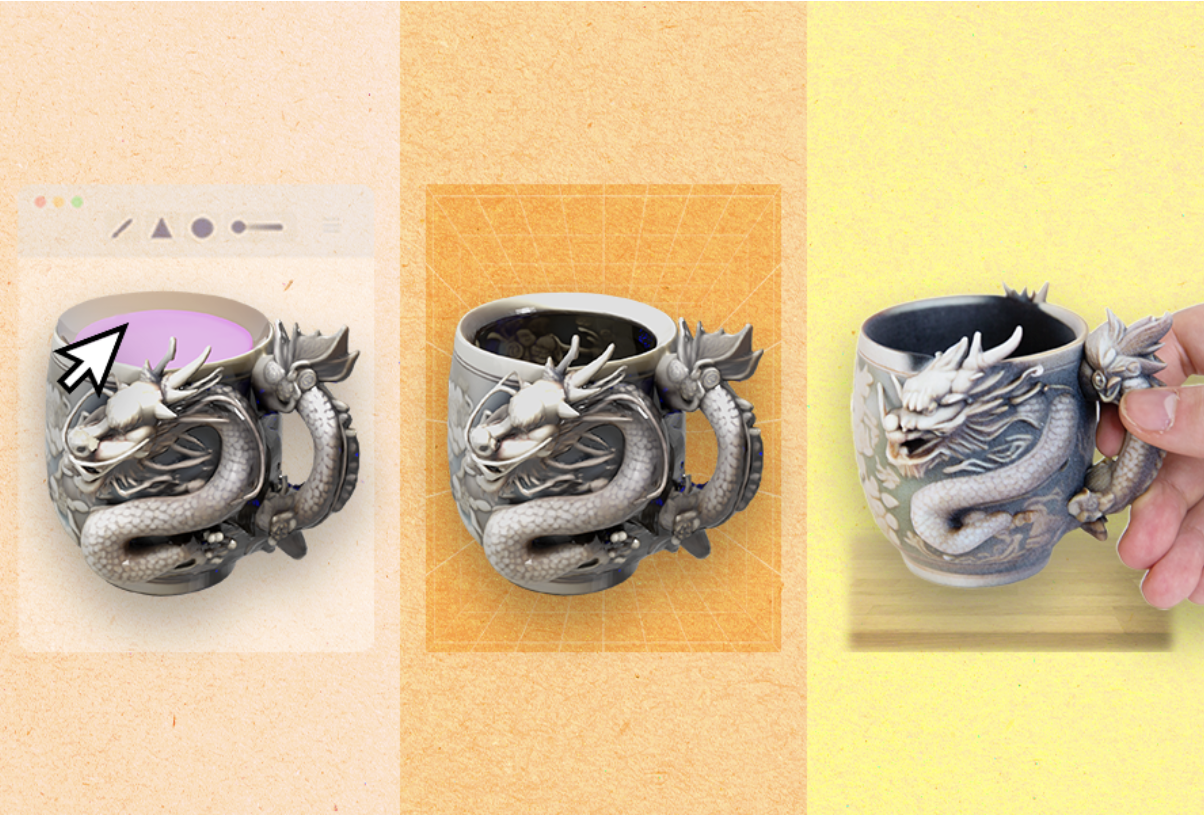
“What you see is what you get” is a guiding principle for many software engineers — create programs where the content you’re editing looks the same as the final product. But when you’re using generative AI (genAI) systems to 3D print, say, a mug, you’ll likely get a cup that can’t hold your coffee. Why is that?
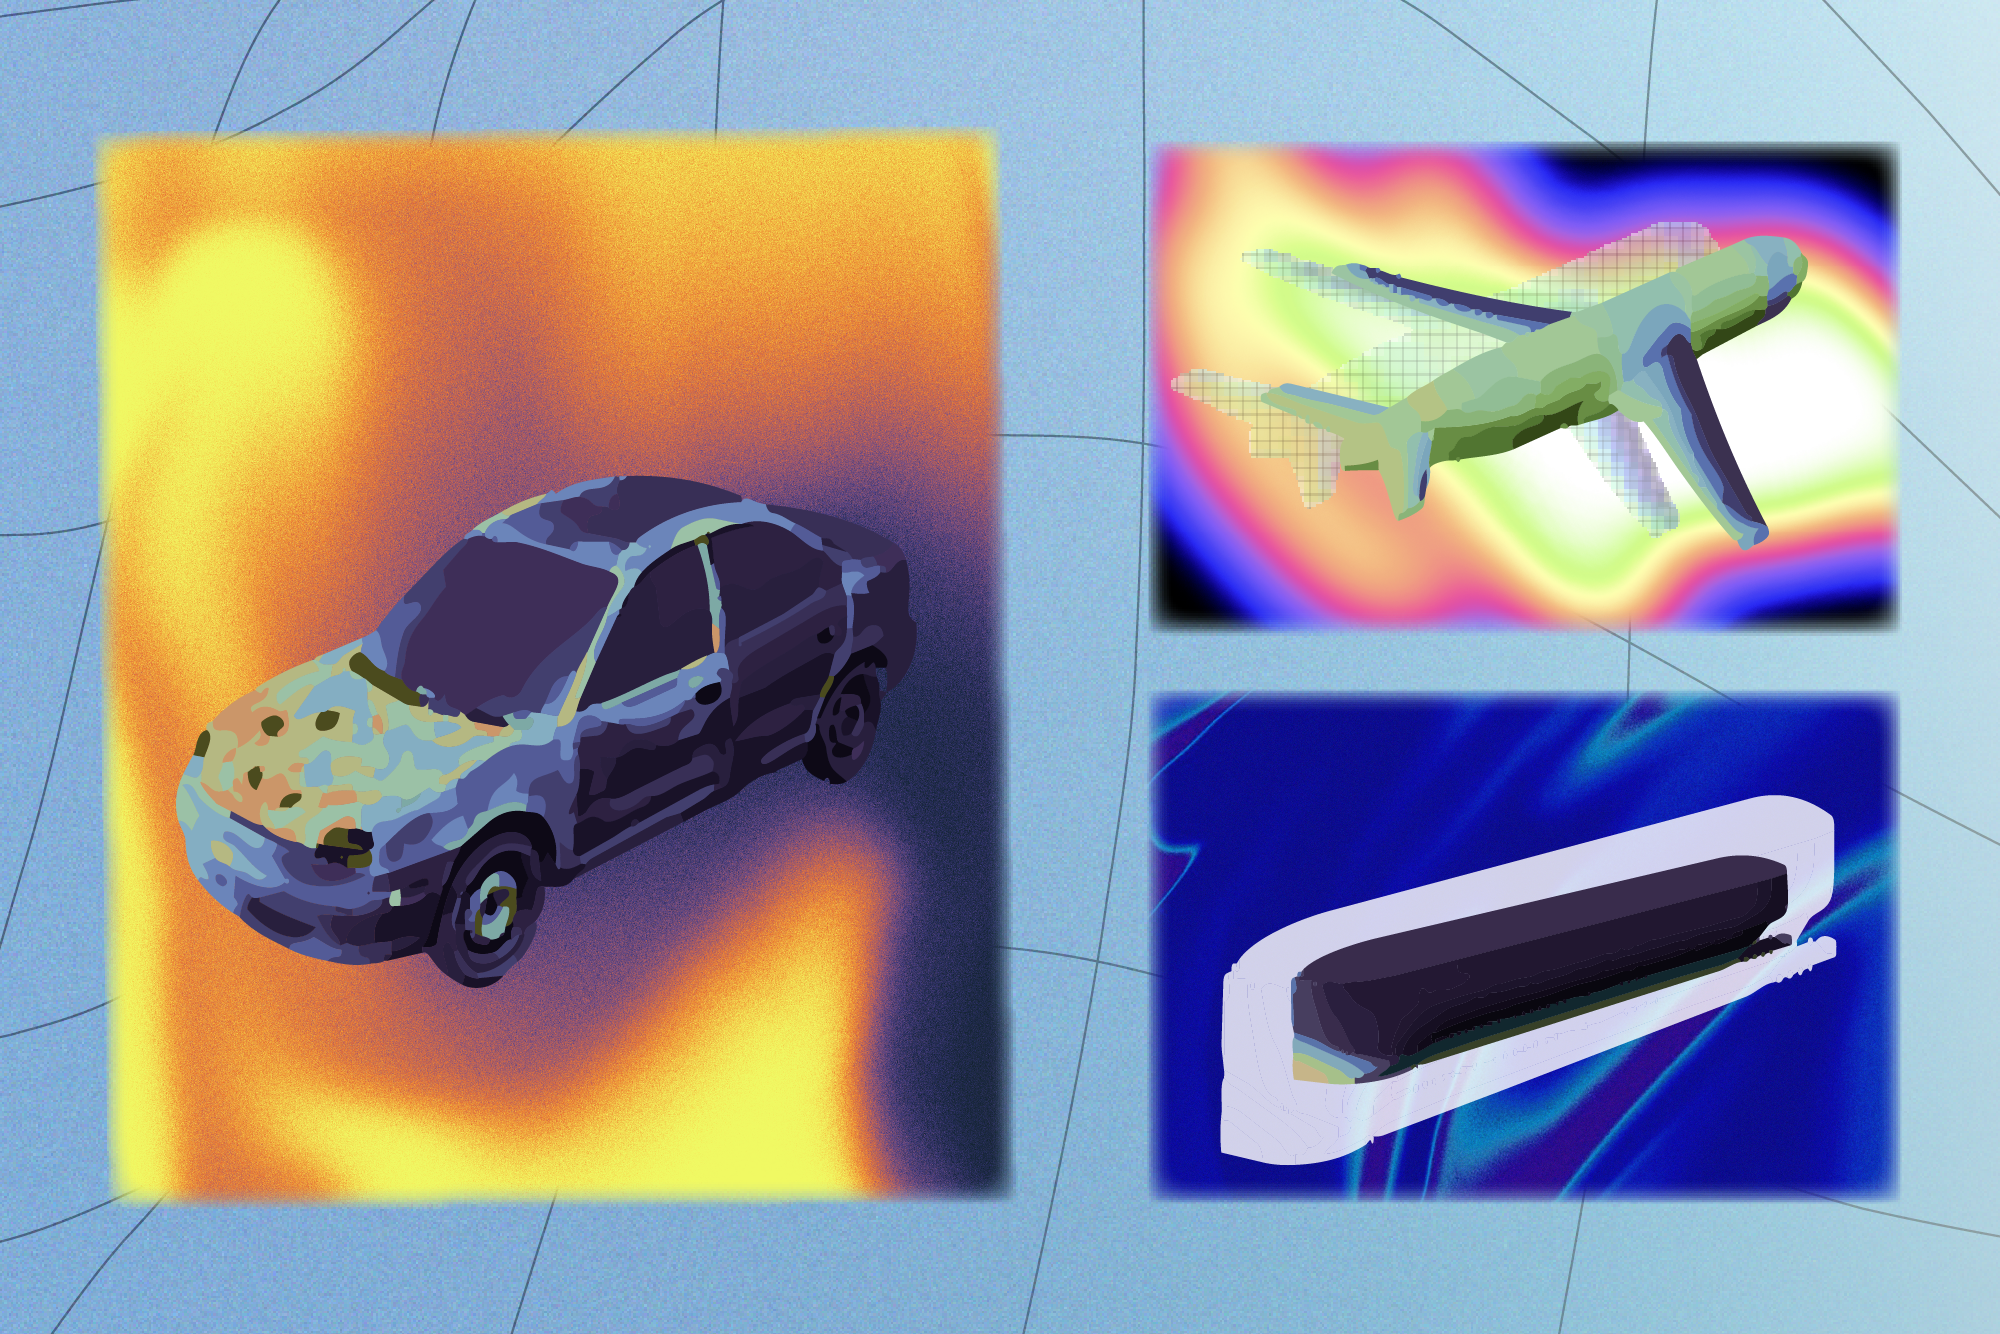
Artificial intelligence models are jacks of many trades, including writing, generating images, and creating 3D models. But they aren’t as helpful when it comes to testing robots or designs for vehicles in diverse environments, since they don’t understand physics as well as they do pixels or text.
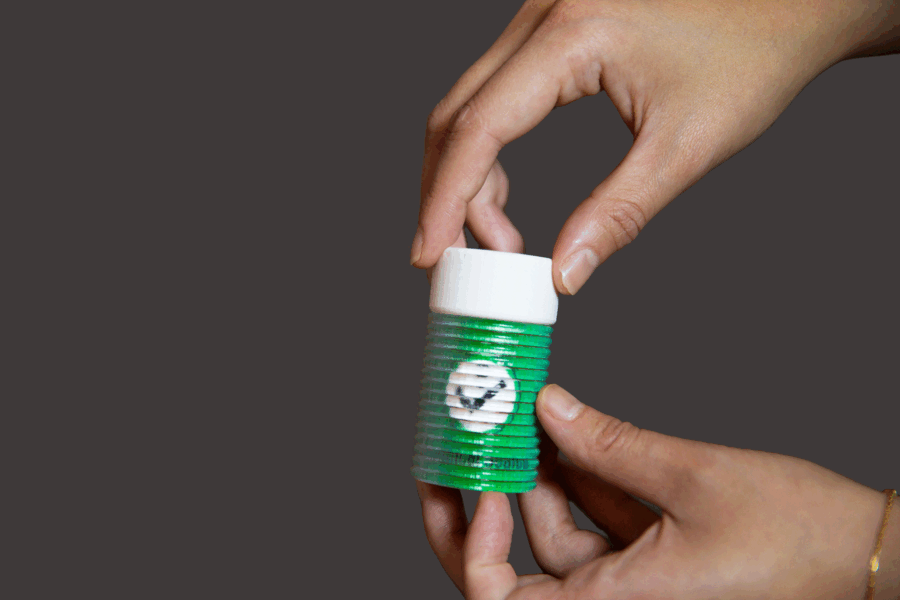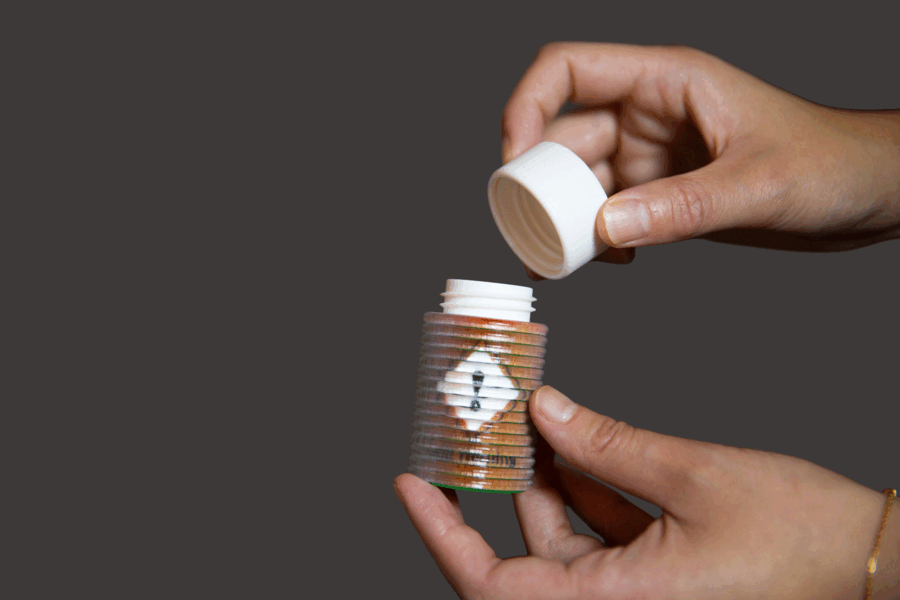
Imagine a bottle of hazardous chemicals sitting on a laboratory shelf that changes its appearance to alert scientists that its lid is not properly secured, potentially preventing a dangerous spill.
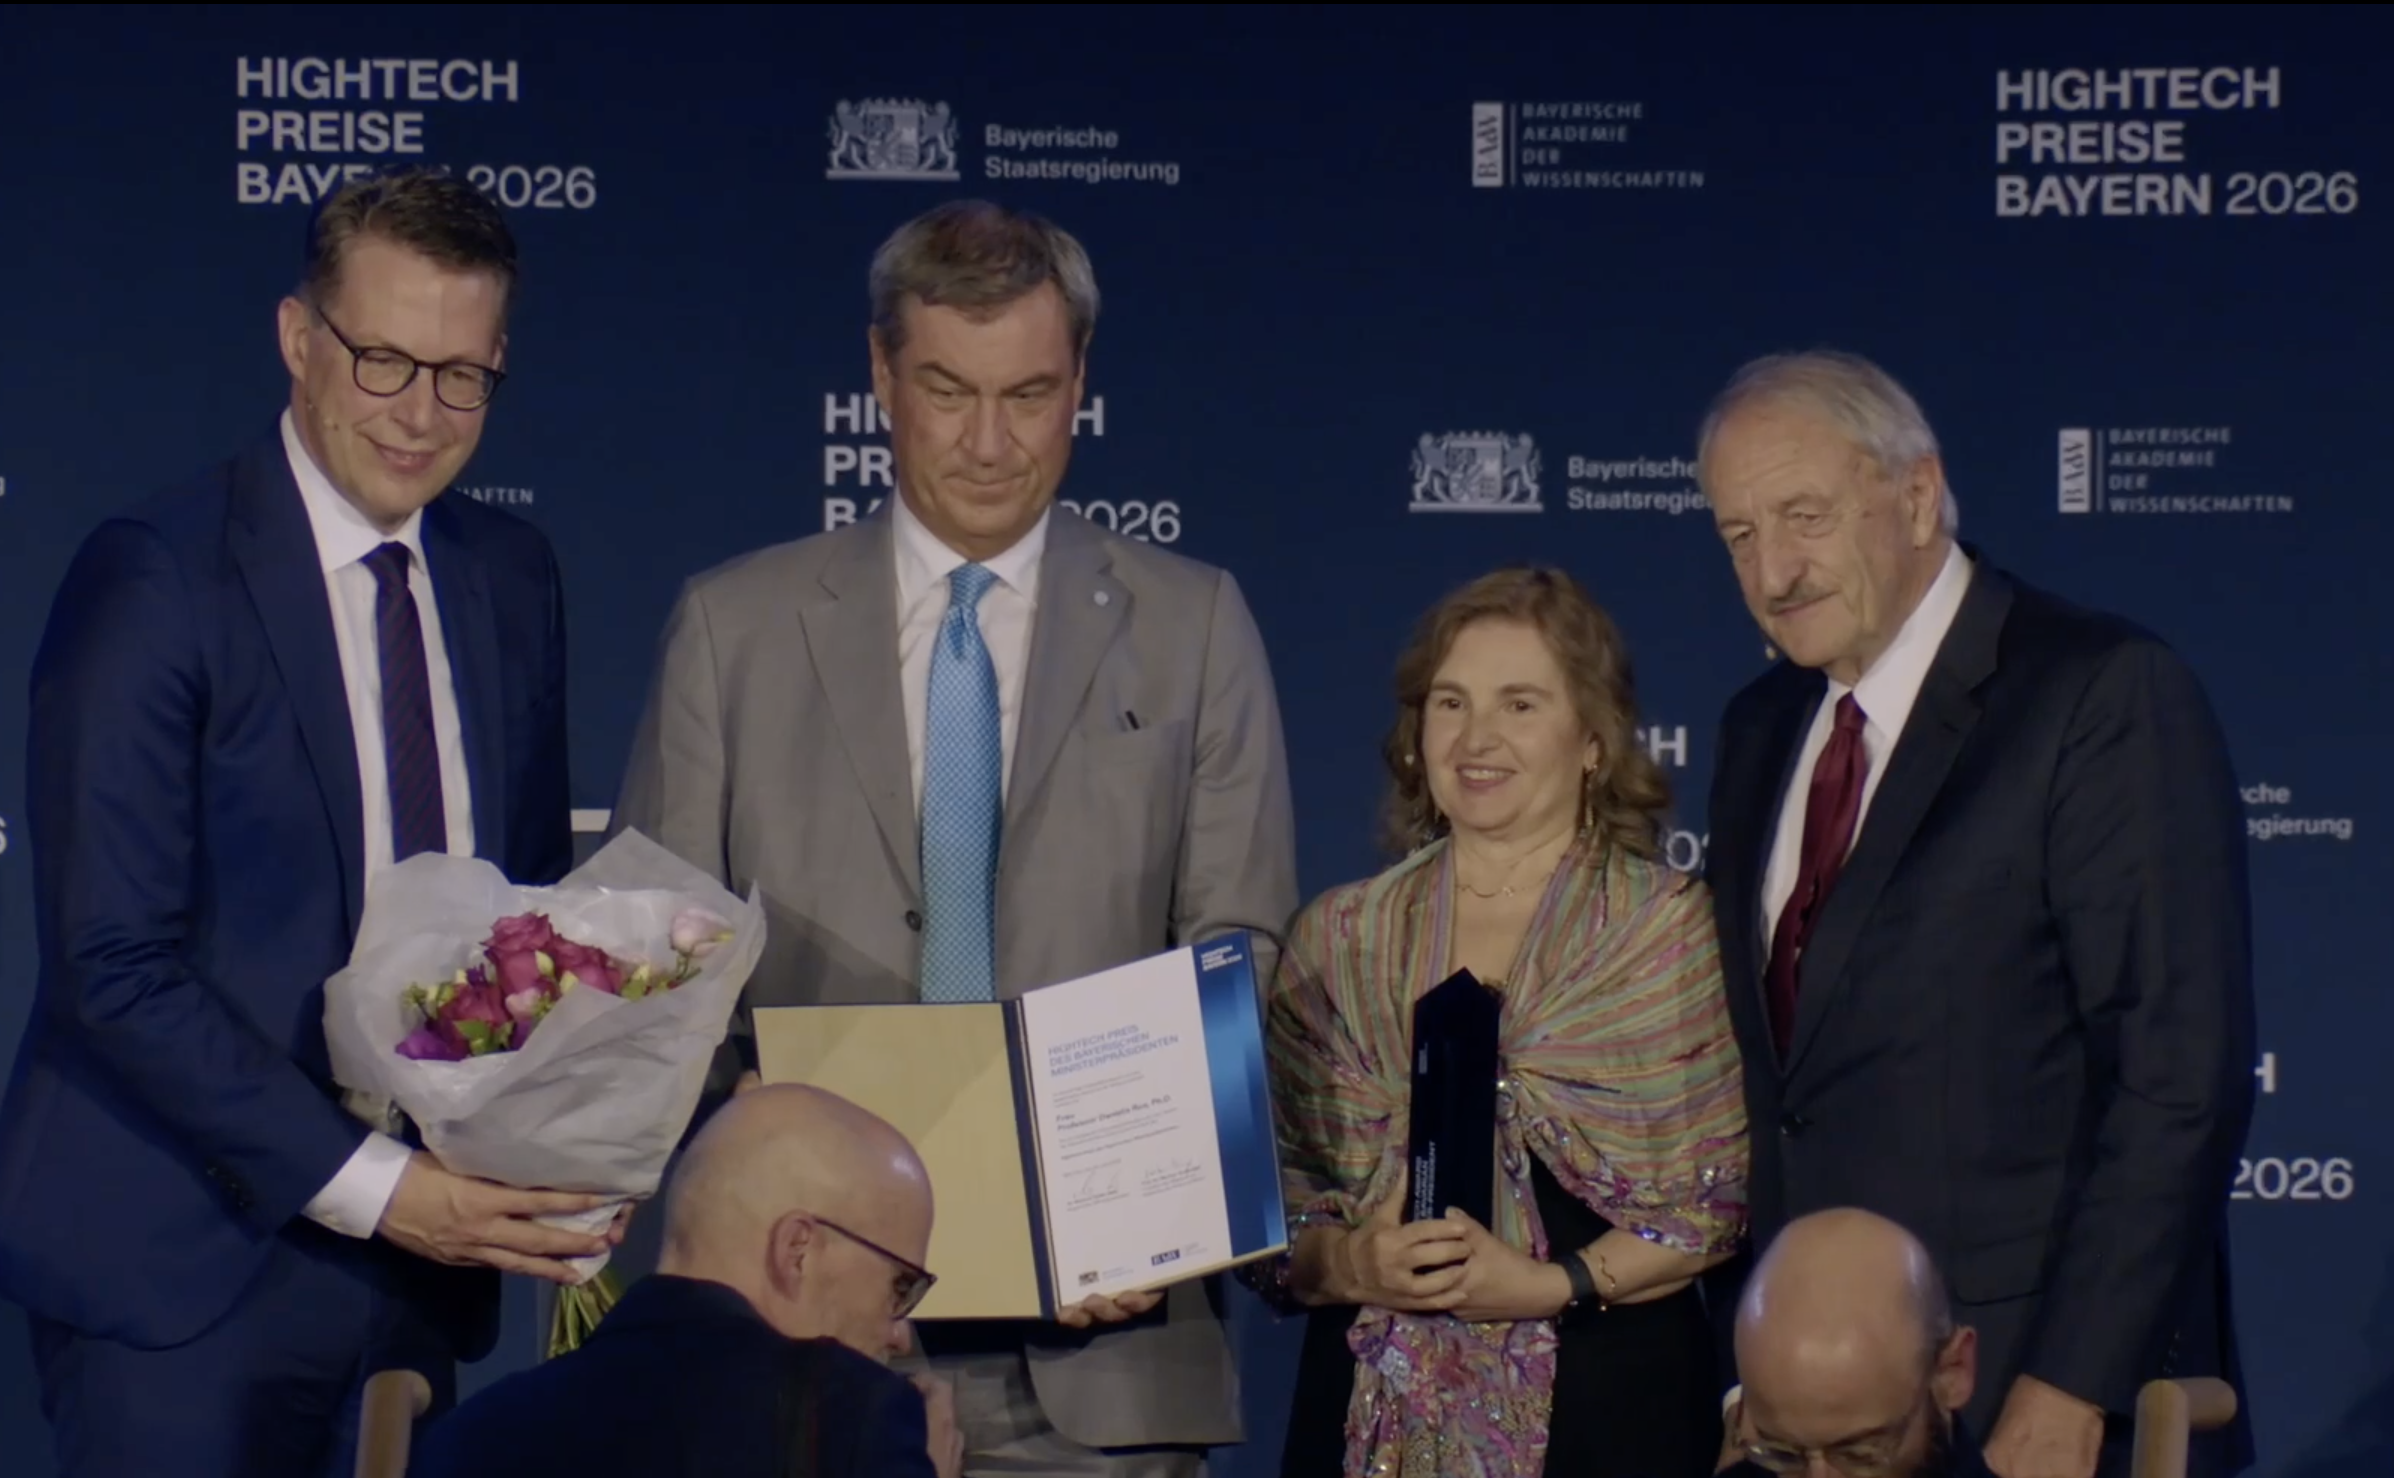
Daniela Rus, Director of MIT CSAIL and the Panasonic Professor of Computer Science, has received the 2026 High-Tech Prize of the Bavarian Minister-President for her contributions to robotics, artificial intelligence, and autonomous systems.
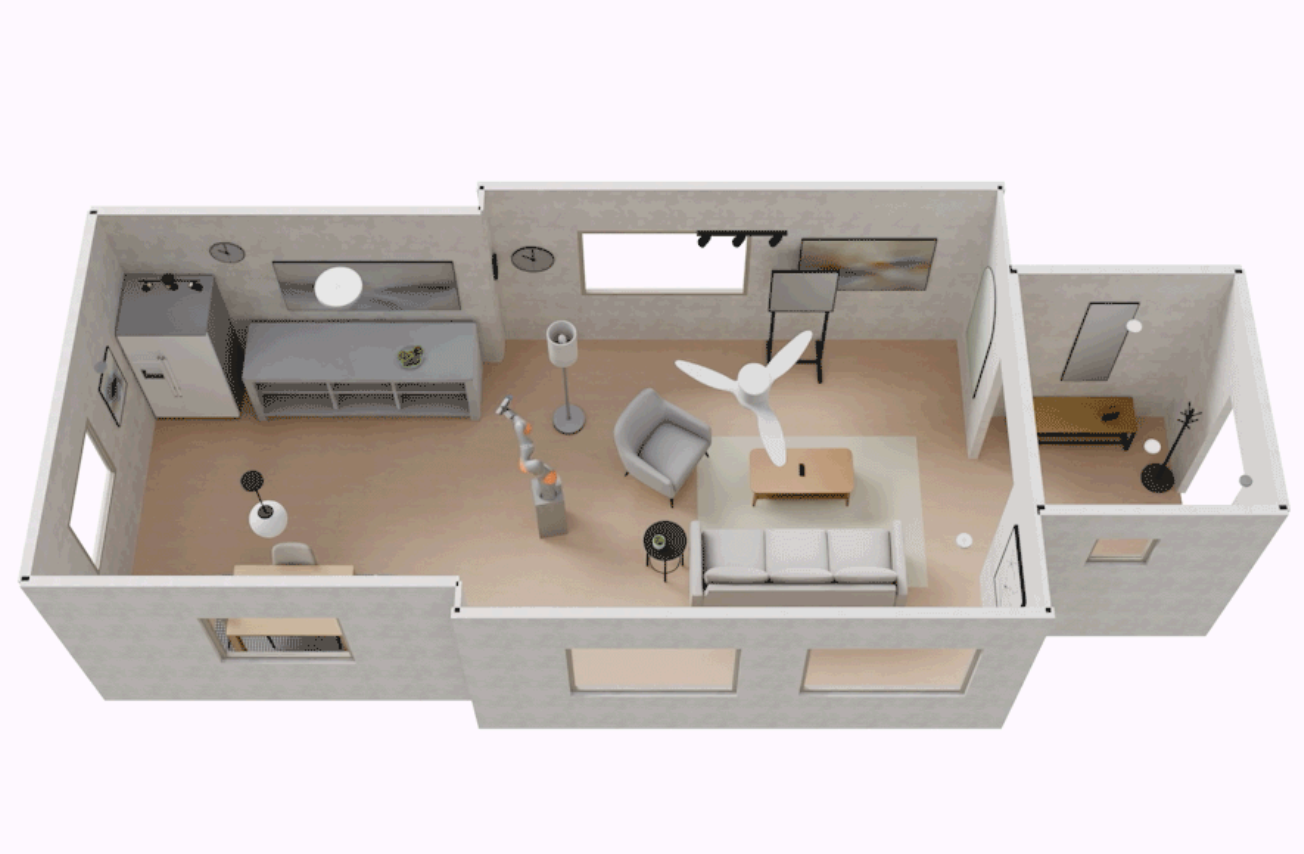
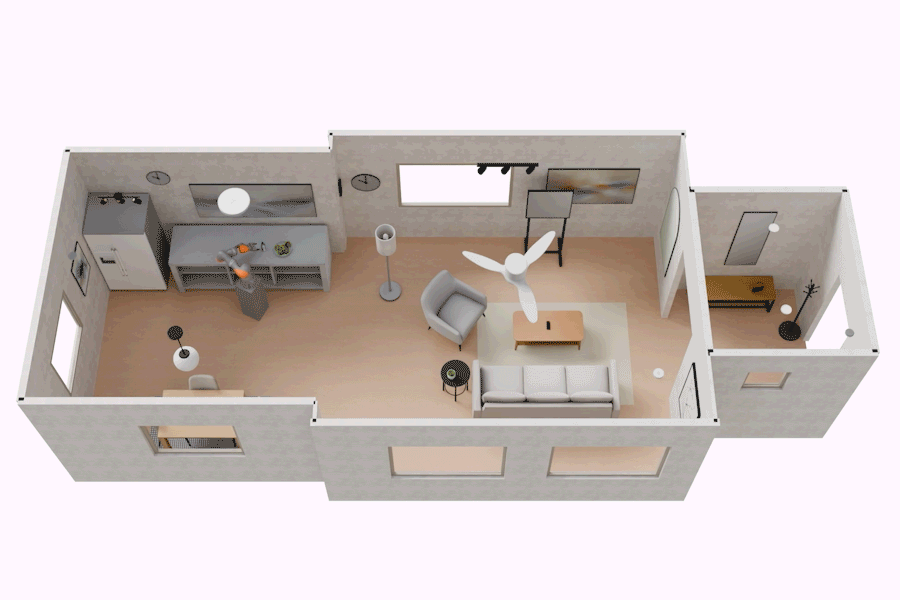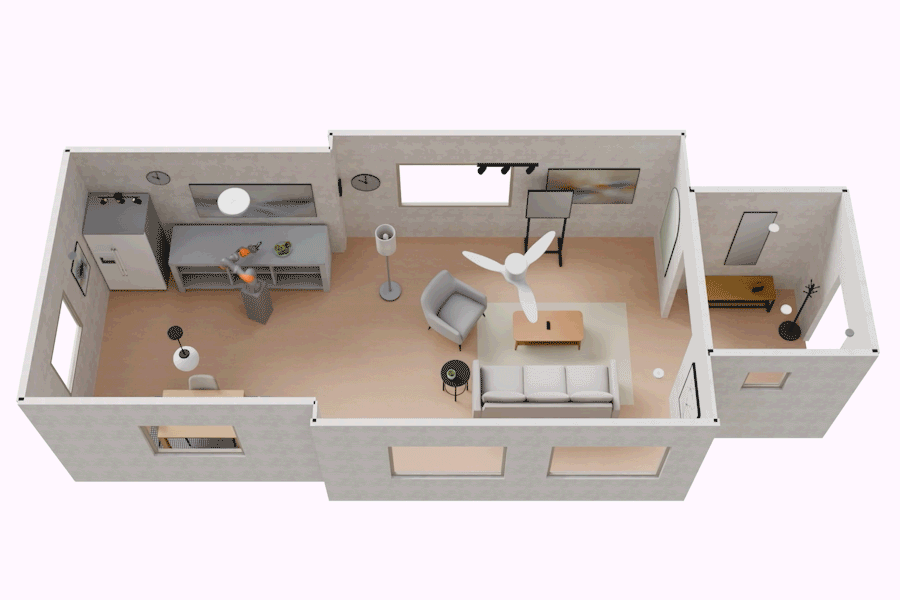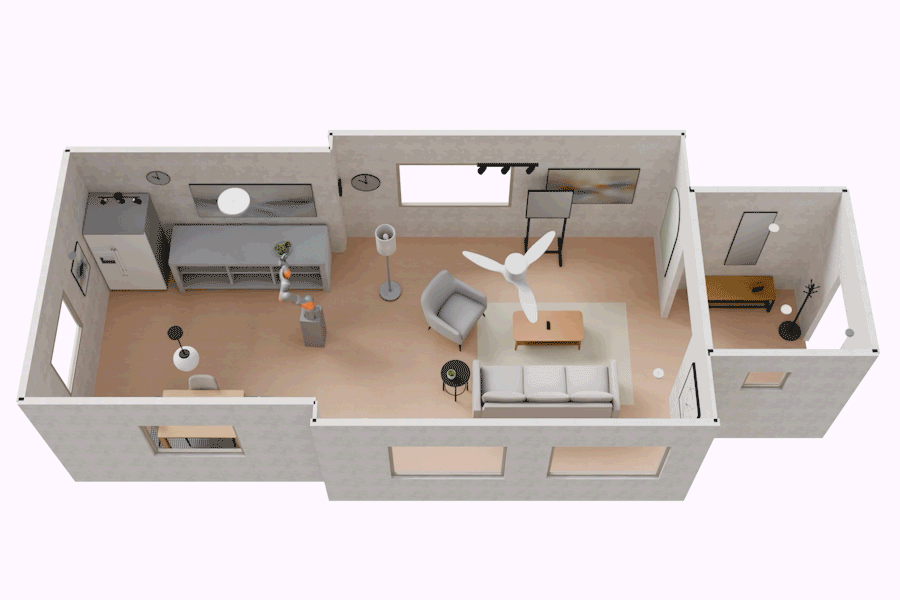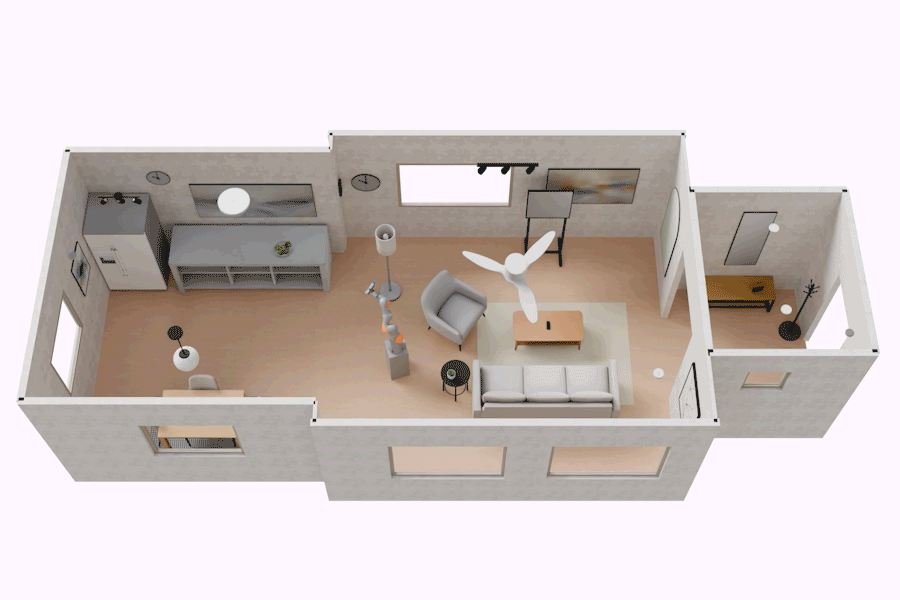
SceneSmith, a new system developed at MIT uses three agents to piece together the objects, walls, and overall look of a 3D scene. Its realistic recreations of indoor spaces help robots practice skills and try out different ways of doing tasks before they’re powered on.
An increasingly common sight: robots walking down the street, surrounded by astounded onlookers. But these machines aren’t yet the do-it-all assistants you’d want working in a kitchen or factory, and a major bottleneck is data. Much like humans, robots learn best by experience. The challenge is that it’s labor-intensive and time-consuming to physically teach these machines so many actions across different settings.
Imagine working at a warehouse or office sometime in the near future, and you’re asked to help a new trainee learn the basics of their job. The catch: It’s a robot. To teach them, you might want to play a game of “show and tell” — that is, physically showing how to do something a few different ways, while also explaining what you’re doing.