In his recent conversation on Building 32, MIT CSAIL Senior Research Scientist David Clark tells a story from 1995 when he got into a conversation with an economist and friend of his. “He said, ‘David, you have to understand the internet is about routing money, and routing packets is a side effect. And you screwed up the money routing protocols.’ And I said, ‘I didn't design any money routing protocols.’ And he said, ‘that's what I said.’”
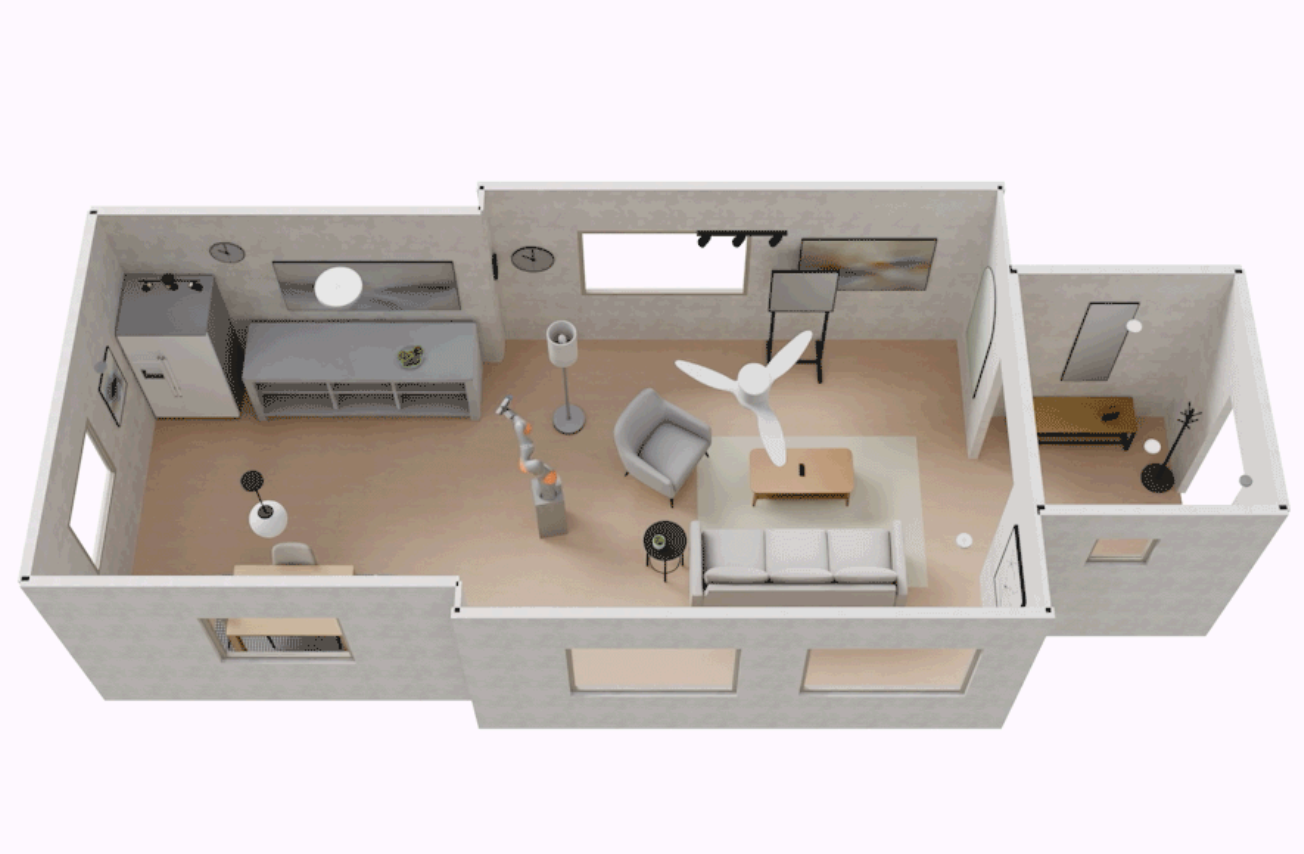
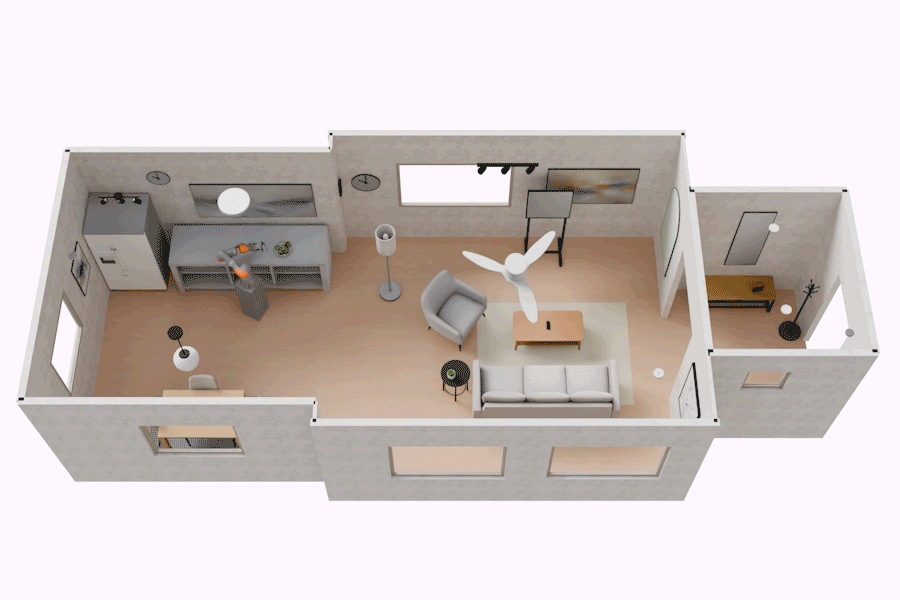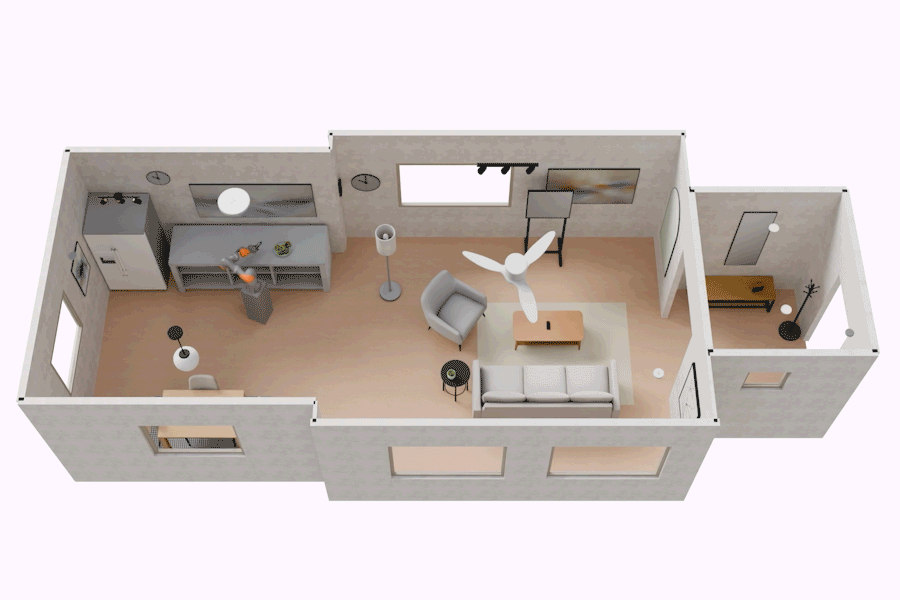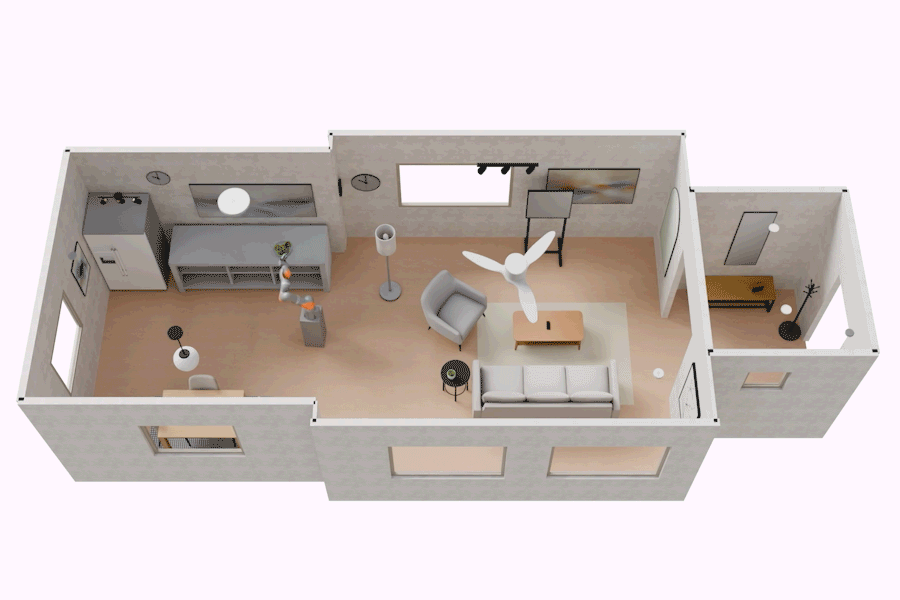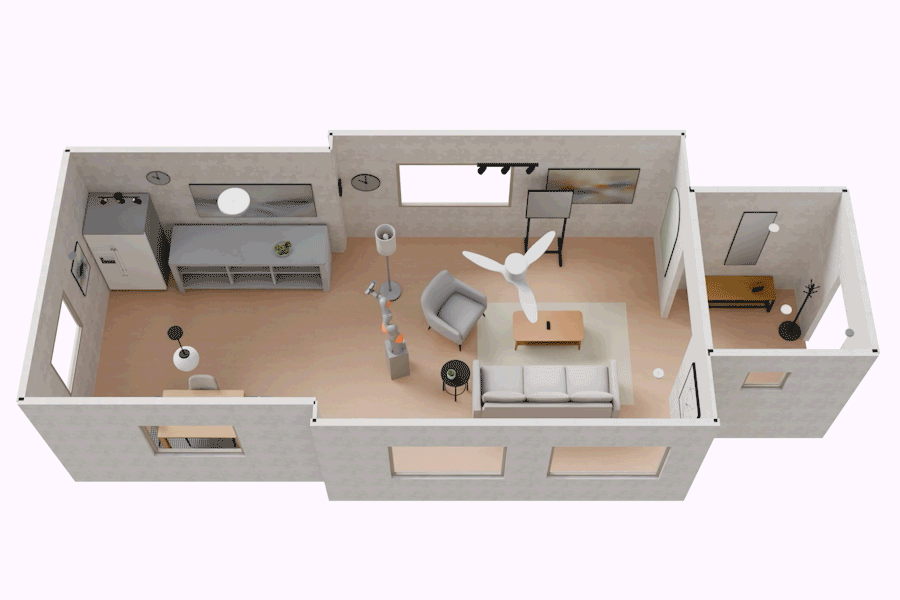
SceneSmith, a new system developed at MIT uses three agents to piece together the objects, walls, and overall look of a 3D scene. Its realistic recreations of indoor spaces help robots practice skills and try out different ways of doing tasks before they’re powered on.
The deployment of automated software systems called AI agents has recently exploded. A November 2025 report by MIT Sloan School of Management and Boston Consulting Group found that 35 percent of surveyed businesses had already deployed AI agents, while another 44 percent planned to implement agentic AI soon.
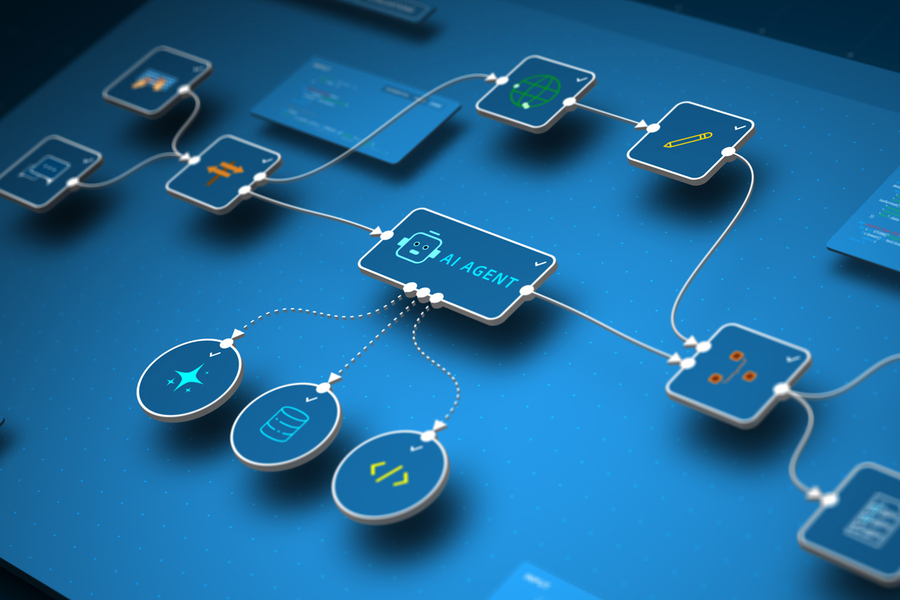
Agentic workflows are artificial intelligence-powered software systems that chain together multiple models and external tools to tackle complicated tasks, like analyzing a video and answering questions about it.
An increasingly common sight: robots walking down the street, surrounded by astounded onlookers. But these machines aren’t yet the do-it-all assistants you’d want working in a kitchen or factory, and a major bottleneck is data. Much like humans, robots learn best by experience. The challenge is that it’s labor-intensive and time-consuming to physically teach these machines so many actions across different settings.
In his 1927 paper, “A law of comparative judgment,” the American psychologist L. L. Thurstone proposed that when people select one option among multiple alternatives, they are picking the one that has the highest value to them, even though they cannot assign a particular number to that choice.