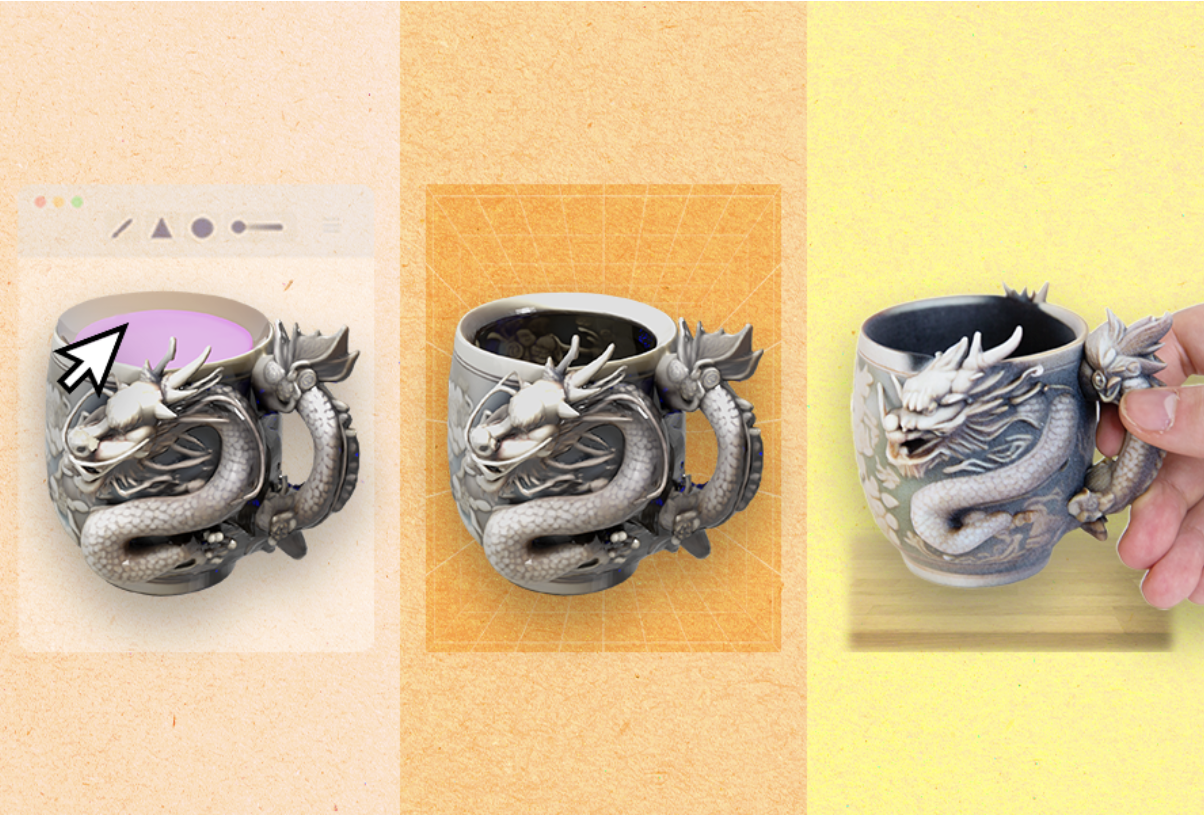
“What you see is what you get” is a guiding principle for many software engineers — create programs where the content you’re editing looks the same as the final product. But when you’re using generative AI (genAI) systems to 3D print, say, a mug, you’ll likely get a cup that can’t hold your coffee. Why is that?
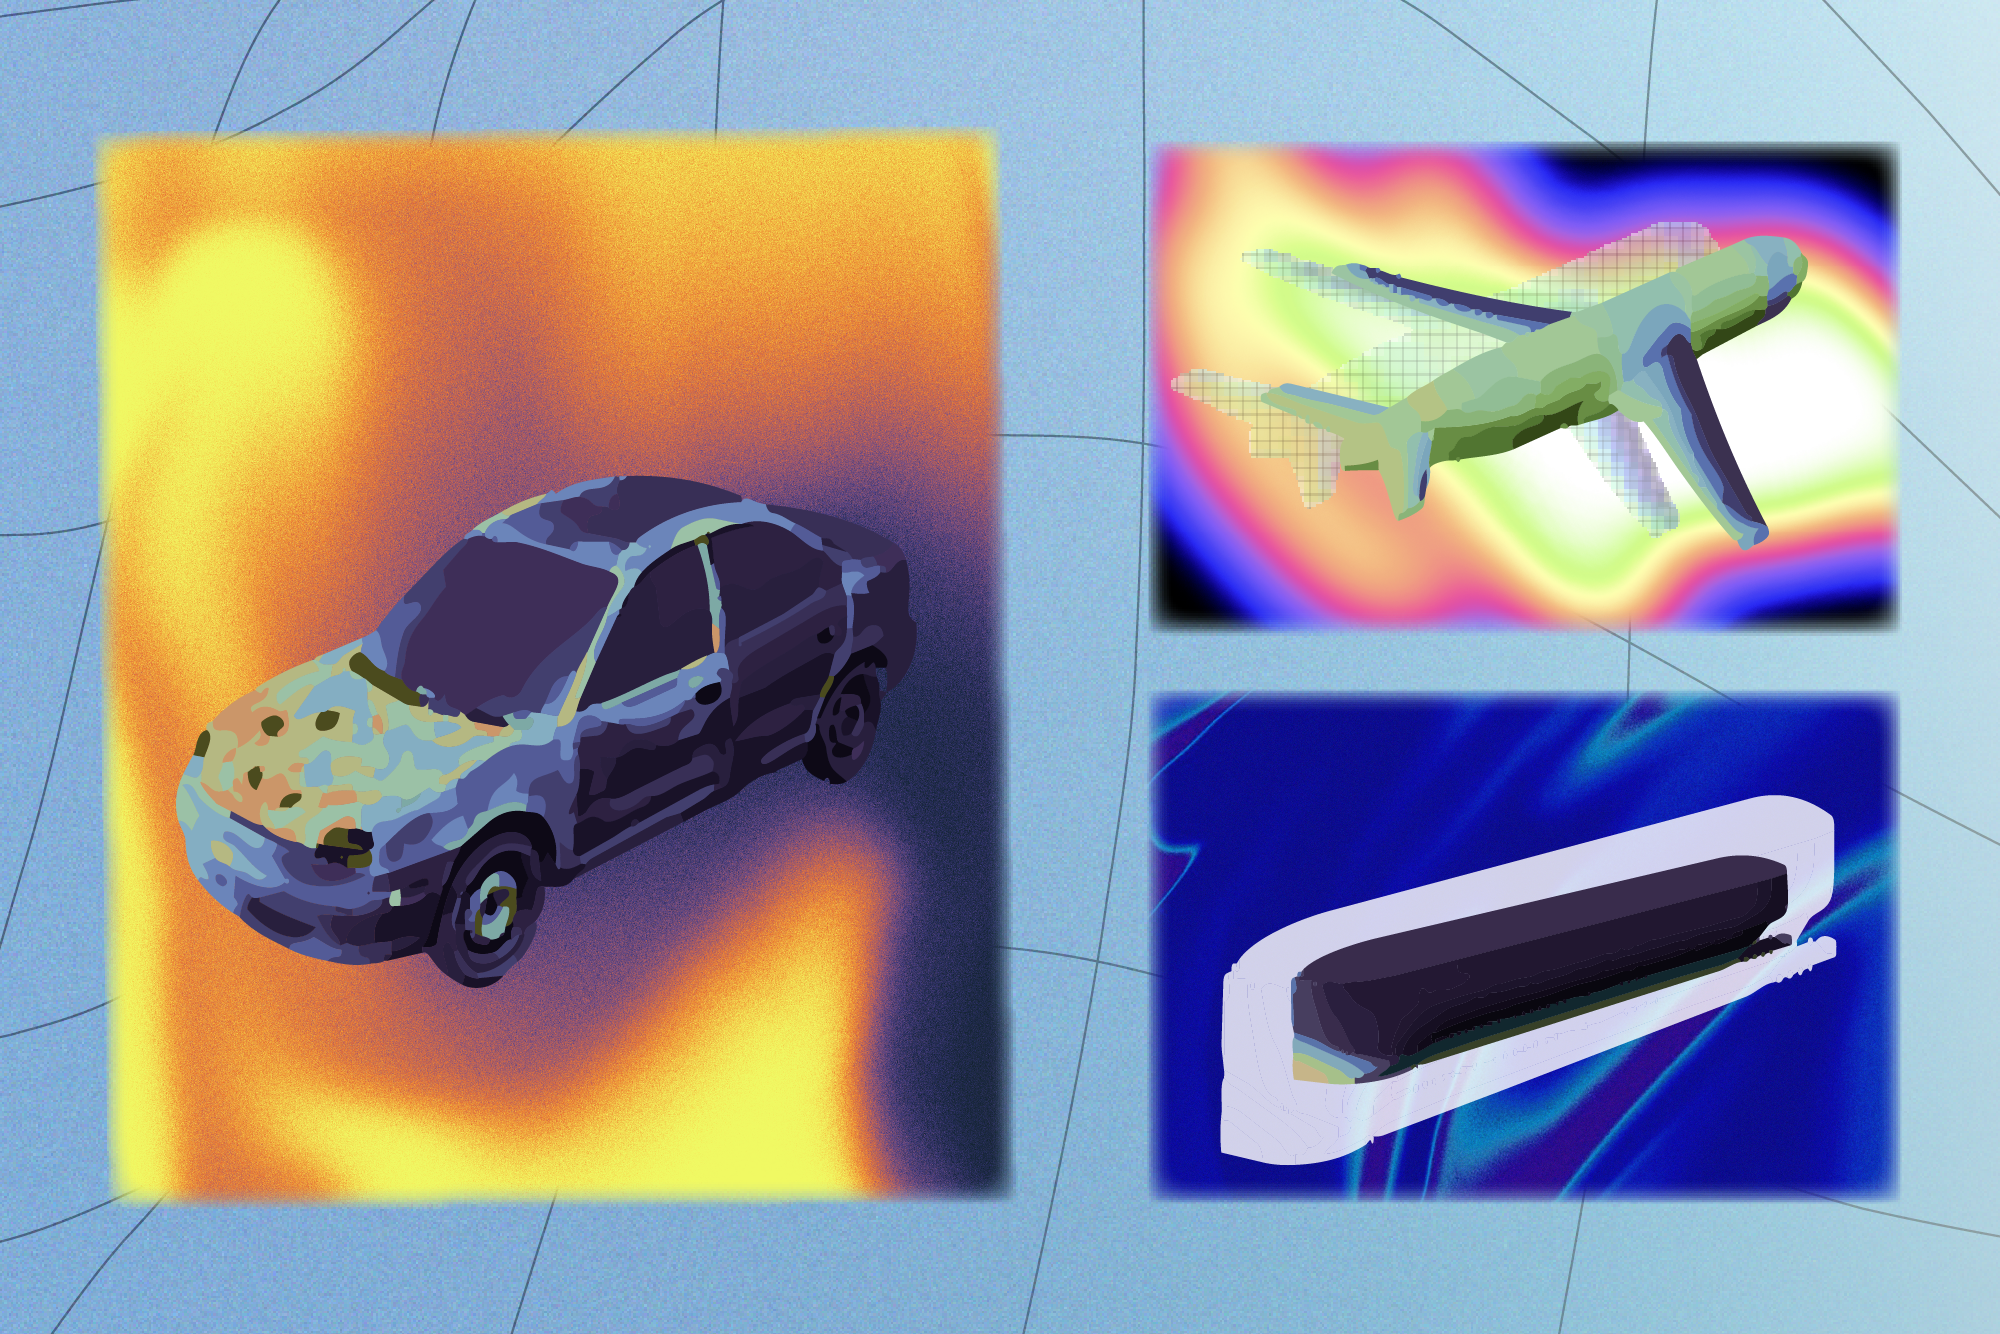
Artificial intelligence models are jacks of many trades, including writing, generating images, and creating 3D models. But they aren’t as helpful when it comes to testing robots or designs for vehicles in diverse environments, since they don’t understand physics as well as they do pixels or text.
Khosla Ventures focuses on high-risk, high-impact investments across artificial intelligence (AI), climate change, sustainability, enterprise, consumer, fintech, digital health, and frontier technologies. In this tech talk, Khosla Ventures will be leading conversations with one of their ventures, Foundry Robotics. Join the team over lunch to learn more about Foundry Robotics and their technology, opportunities to work at Foundry Robotics, Khosla Ventures, and more of Khosla Ventures' portfolio companies.
Andrew W. Lo, MIT Professor in the Sloan School of Management, CSAIL PI, and Faculty Co-Director of FinTechAI@CSAIL, says, "The question is: `Do large language models have our back?’ The answer is no, not yet.”
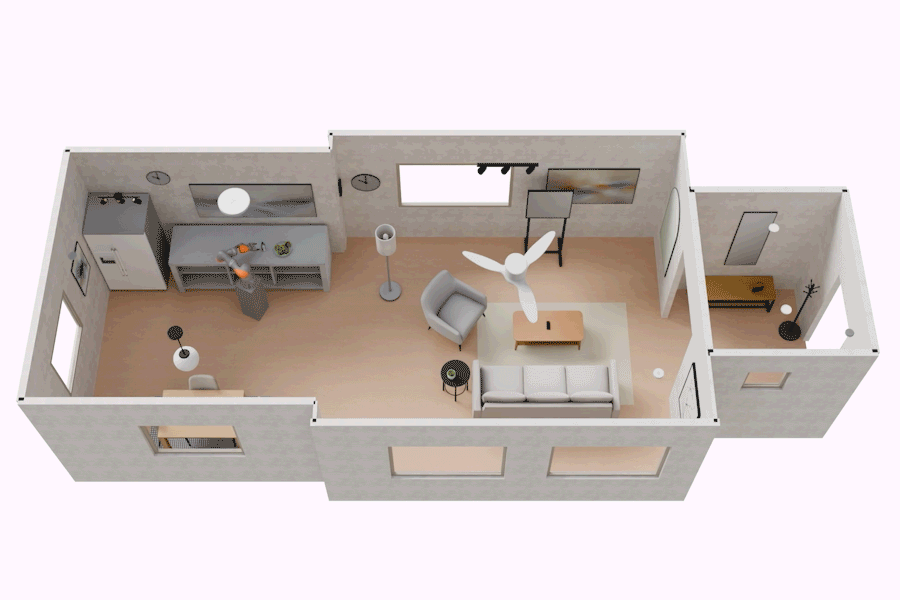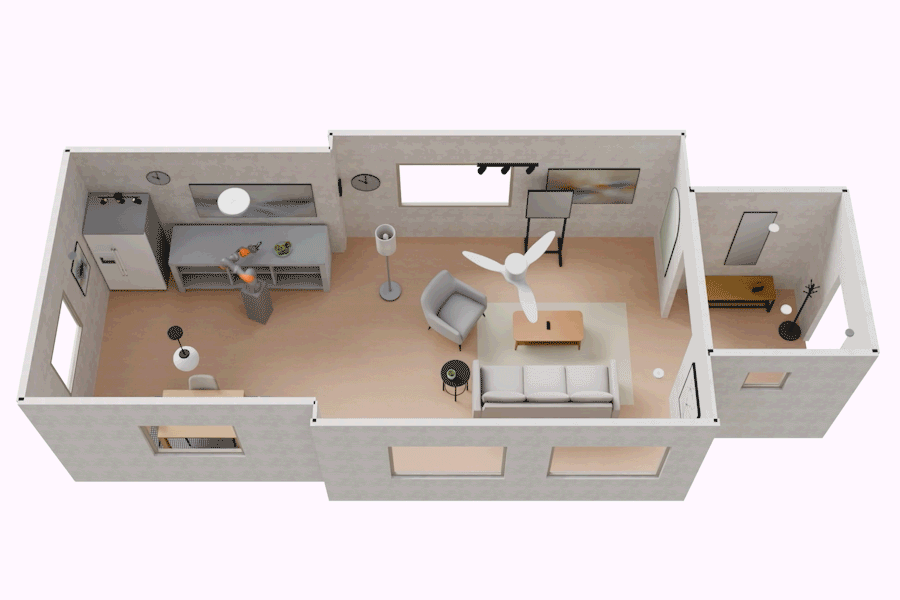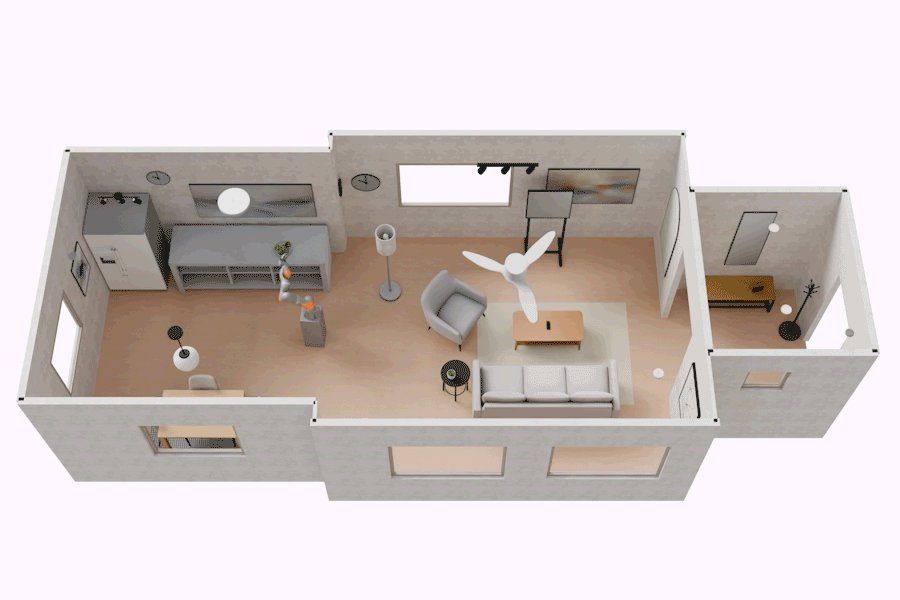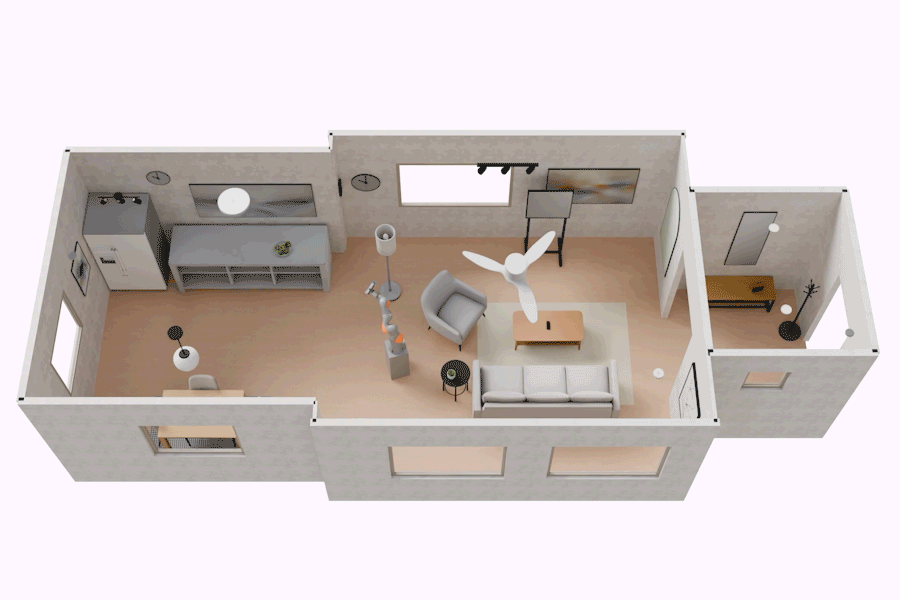
An increasingly common sight: robots walking down the street, surrounded by astounded onlookers. But these machines aren’t yet the do-it-all assistants you’d want working in a kitchen or factory, and a major bottleneck is data. Much like humans, robots learn best by experience. The challenge is that it’s labor-intensive and time-consuming to physically teach these machines so many actions across different settings.
An algorithm flags a patient as high risk for sepsis; a risk score informs whether a woman receives additional cancer screening; a deterioration model triggers an alert that sends a care team to a bedside.
To accelerate and refine decision-making in a fast-paced, global marketplace, enterprises may deploy generative artificial intelligence models to help summarize and interpret the charts that often fill market summaries and financial reports.
For MIT Professor Armando Solar-Lezama, one of the most common misunderstandings about AI is the notion that it can be dropped into existing human roles like a plug-and-play replacement.